

04 · RESEARCH TOPIC
Delay-Tolerant Networks
Spacecraft drift in and out of reach, so a path from sender to receiver is often missing. Delay-tolerant networks keep the data on board and pass it on when the next link opens. I design the plans and the routing that decide where it goes next.
A signal from Earth takes between 3 and 22 minutes to reach Mars, depending on where the two planets are. Orbiters, landers and ground stations see each other only now and then, as they move and the planets turn. The internet's protocols expect a live path from sender to receiver, and they give up when there is none.
Delay-tolerant networks work another way: each node keeps the data and hands it on at the next contact. Spacecraft follow known orbits, so most contacts can be predicted and listed in advance in a contact plan. Contact graph routing uses that plan to choose the next hop, and my routing modules run in NASA's ION and HDTN software. With students and colleagues, I also study what to do when the plan turns out wrong, how to schedule laser links at Mars, and how to see a whole interplanetary network at a glance.
A signal takes 3 to 22 minutes to reach Mars, depending on where the two planets are.
Route a bundle
My tutorial on contact graph routing, written with Olivier De Jonckère and Scott Burleigh, works through one small network by hand: two ground stations, a mission control centre and two satellites, linked by contacts that open and close within one minute. Pick when a bundle of data is created, where it starts and where it should go. The tool searches the contact plan for the earliest delivery, as the tutorial does.
- created
- in flight, 1 s per hop
- stored, waiting for a contact
- delivered
- contact used
- Delivered at3 s
- Waiting0 s
Contacts and light times as in the tutorial's example (Fig. 3a), with 1 s of light time on every hop. The search returns the earliest arrival, as in its Algorithms 1 to 3; bundle size, queues and contact capacity are left out.
The contact plan behind this
From Fig. 3a of Routing in the Space Internet: A contact graph routing tutorial (Journal of Network and Computer Applications, 2021). A and C are ground stations, B is mission control, D and E are satellites. Each link works both ways as two one-way contacts: #1/2 is contact 1 from A to B and contact 2 from B to A. Every contact has rate 1 and a range of 1 light-second.
| Contacts | Between | Start (s) | End (s) |
|---|---|---|---|
| #1/2 | A and B | 0 | 60 |
| #3/4 | B and C | 0 | 60 |
| #5/6 | A and C | 0 | 60 |
| #7/8 | C and D | 0 | 30 |
| #9/10 | A and E | 10 | 20 |
| #11/12 | D and E | 0 | 10 |
| #13/14 | D and E | 30 | 40 |
| #15/16 | D and E | 50 | 60 |
The paper's worked example sends a bundle from A to E at t = 0. Its route search (Fig. 8) finds Route 1, from A to C, C to D and D to E, delivered at t = 3 s with no waiting: each of the three hops adds 1 s of light time. The direct contact from A to E opens at t = 10 and would deliver at t = 11 s. Its Route 3 keeps the bundle stored at D until the next contact to E at t = 30 and delivers at t = 31 s.
Results, with sources
- Tested in orbit. In December 2020 and May 2021, ESA's OPS-SAT satellite stored and forwarded a web request and its reply between a simulated offline site and a site with internet access. The paper reports it as the first successful test in space of version 7 of the Bundle Protocol, the standard for this kind of networking. Ring Road Networks, IEEE Comm. Magazine 2022, In-Orbit Validation In simulations of ten remote ground stations, the average delivery time fell from 7.7 hours with one small satellite to 1.3 hours with 20. Ring Road Networks, Fig. 2b
- Laser links at Mars. In 24-hour simulations of Mars orbiters with one laser each, relaying science data to Earth, a scheduler that plans every link around the flow of data toward Earth could send back 1.5 to 2 times as much data as an earlier automatic method. Mars laser scheduling, IEEE WiSEE 2024, Fig. 4a
- A network to another star. As a thought experiment, a chain of relay spacecraft could span the 39.5 light-years to the TRAPPIST-1 planetary system, each relay keeping a copy and resending whatever its hop loses. A message would arrive after 39.58 years if 1 packet in 1,000 is lost on each hop, and after 59.25 years if 1 in 5 is. With very clean links, about 15,000 small relays about a light-day apart look like a reasonable first estimate. The paper assumes hardware that does not exist yet. Networking in Interstellar Dimensions, IEEE TAES 2019, Table III and §V
Tools and projects
-
IPN-V
The Interplanetary Network Visualiser: a 3D view of orbiters, landers and ground stations across the Solar System, with their contacts and light-time delays. The Mars network on the home page comes from one of its scenarios. Demo on request.
-
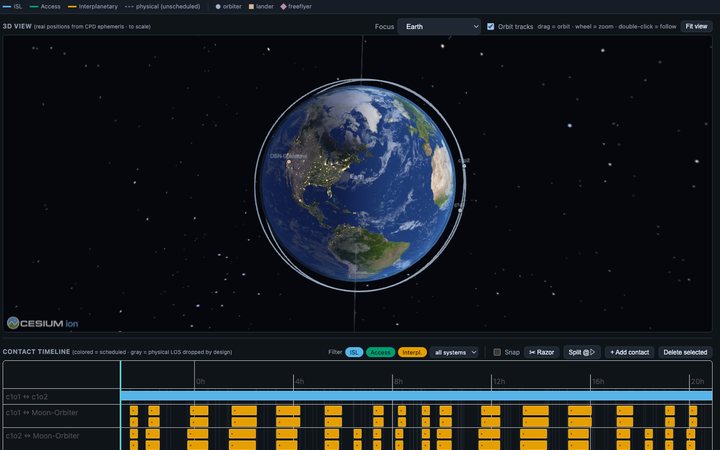
Contact Plan Designer
Works out when spacecraft and ground stations can talk to each other and turns it into the contact plans that DTN routing needs. Runs in the browser and as a plug-in for STK.
-
Figure © 2017 IEEE DtnSim
A simulator for studying delay-tolerant networks: routing, forwarding, scheduling and contact planning.
-
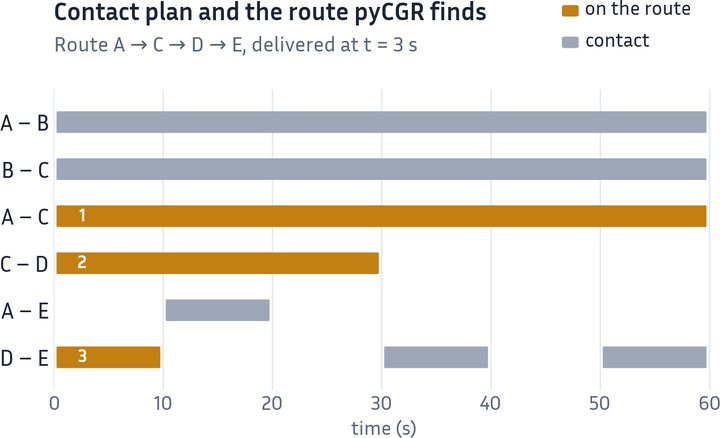
pyCGR and A-SABR
Contact graph routing in Python, adopted in NASA's HDTN, and an adaptive library for the wider family of schedule-aware bundle routing.
-
MISSION
Models in Space Systems: formal models and uncertainty-aware routing for space networks, with U. Twente, RWTH Aachen, Saarland University, UNC, UNRC, D3TN, Ascentio and INVAP.
Responsible researcher
-
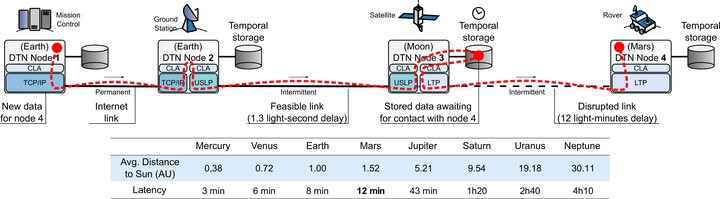
Figure © 2020 Elsevier VISTA and a Solar System Internet twin
Viable and scalable interplanetary architectures, coordinated by Olivier De Jonckère at LIRMM, and a doctoral project co-funded by ESA on a digital twin to plan and operate networks across the Solar System.
Collaborator · co-supervisor


My routing code also runs in ION and HDTN, and I took part in developing µD3TN. More on the software page.
Selected papers
-
Comparing Statistical, Analytical, and Learning-Based Routing Approaches for Delay-Tolerant Networks
ACM Transactions on Modeling and Computer Simulation, 2025
Abstract
In delay-tolerant networks (DTNs) with uncertain contact plans, the communication episodes and their reliabilities are known a priori . To maximise the end-to-end delivery probability, a bounded network-wide number of message copies are allowed. The resulting multi-copy routing optimization problem is naturally modelled as a Markov decision process with distributed information. In this paper, we provide an in-depth comparison of three solution approaches: statistical model checking with scheduler sampling, the analytical RUCoP algorithm based on probabilistic model checking, and an implementation of concurrent Q-learning. We use an extensive benchmark set comprising random networks, scalable binomial topologies, and realistic ring-road low Earth orbit satellite networks. We evaluate the obtained message delivery probabilities as well as the computational effort. Our results show that all three approaches are suitable tools for obtaining reliable routes in DTN, and expose a tradeoff between scalability and solution quality.
-
Autonomous Max-Flow Interplanetary Laser Link Scheduling for Martian Exploration
IEEE International Conference on Wireless for Space and Extreme Environments (WiSEE), 2024
Abstract
New communication technologies like delay and disruption-tolerant networking (DTN) and free-space laser communications are being developed to handle massive planetary telemetry data. However, existing infrastructure cannot meet the scalability and autonomy demands of future space missions, resulting in 95% of data left on the mission planet. Manual scheduling of deep-space laser transmissions by operators is inefficient and error-prone, limiting mission parallelization, while autonomous scheduling, though promising, may limit optimal network routes reducing the network capacity. We hypothesize that autonomously scheduling contact opportunities will enable acquisition, tracking, and pointing (ATP) for free-space lasers and increase the capacity of interplanetary backhaul networks. In this work, we propose the Laser Link Scheduler (LLS), which combines a novel max-flow network capacity model and a decision-making algorithm for contact selection. We define a series of deep-space communication scenarios where data is collected from orbiters around Mars and backhauled to Earth. LLS is evaluated in simulations using contact plans generated based on realistic conditions and orbital dynamics. Our results confirm that autonomous contact scheduling increases network capacity by 1.5-2x, reducing operational costs and enabling highly parallel space exploration missions.
-
Ring Road Networks: Access for Anyone
IEEE Communications Magazine, 2022
Abstract
Several billion people currently lack reliable access to the Internet and thus to a tremendous source of knowledge. In this article, we describe a field-tested communication approach combining CubeSat platforms and delay-tolerant networking (DTN) solutions to provide asynchronous connectivity to populations and regions that are underserved by the Internet. The resulting class of networks is known as ring road networks (RRNs), a networking approach that is built on technology developed for the construction of a solar system Internet. The necessary self-sufficiency of DTN nodes enables network access to be deployed incrementally at low cost, supporting communities that cannot be profitably served by Internet satellite constellations. We present the RRN architecture and evaluate the expected performance by means of simulations. Based on the latter, we discuss µD3TN: a lightweight and open source DTN protocol stack for RRNs and other DTN classes. µD3TN has been flight-tested in ESA's OPS-SAT in low Earth orbit during December 2020 and May 2021. This work discusses the experiment results as we validated the RRN approach in concrete application use cases. The reported outcomes motivate a new application domain.
-
Routing in the Space Internet: A contact graph routing tutorial
Elsevier Journal of Network and Computer Applications, 2021
Abstract
A Space Internet is possible, as long as the delay and disruption challenges imposed by the space environment are properly tackled. Because these conditions are not well addressed by terrestrial Internet, more capable Delay-Tolerant Networking (DTN) protocols and algorithms are being developed. In particular, the principles and techniques for routing among ground elements and spacecraft in near-Earth orbit and deep-space are enacted in the Contact Graph Routing (CGR) framework. CGR blends a set of non-trivial algorithm adaptations, space operations concepts, time-dynamic scheduling, and specific graph models. The complexity of that framework suggests a need for a focused discussion to facilitate its direct and correct apprehension. To this end, we present an in-depth tutorial that collects and organizes first-hand experience on researching, developing, implementing, and standardizing CGR. Content is laid out in a structure that considers the planning, route search and management, and forwarding phases bridging ground and space domains. We rely on intuitive graphical examples, supporting code material, and references to flight-grade CGR implementations details where pertinent. We hope this tutorial will serve as a valuable resource for engineers and that researchers can also apply the insights presented here to topics in DTN research.
-
Assessing Contact Graph Routing Performance and Reliability in Distributed Satellite Constellations
Journal of Computer Networks and Communications, 2017
Abstract
Existing Internet protocols assume persistent end-to-end connectivity, which cannot be guaranteed in disruptive and high-latency space environments. To operate over these challenging networks, a store-carry-and-forward communication architecture called Delay/Disruption Tolerant Networking (DTN) has been proposed. This work provides the first examination of the performance and robustness of Contact Graph Routing (CGR) algorithm, the state-of-the-art routing scheme for space-based DTNs. To this end, after a thorough description of CGR, two appealing satellite constellations are proposed and evaluated by means of simulations. Indeed, the DtnSim simulator is introduced as another relevant contribution of this work. Results enabled the authors to identify existing CGR weaknesses and enhancement opportunities.
People and partners
- Fernando Raverta, PhD at UNC (2024), co-supervised with Jorge M. Finochietto: routing when the contact plan is uncertain.
- Jason Gerard, PhD at Concordia University (2026, with distinction), co-supervised with Sandra Céspedes: laser links and contact plans for Mars and beyond.
- Alice Le Bihan, PhD student at INSA Lyon and Inria, co-supervised with Pierre François: IPN-V and a digital twin for the Solar System Internet.
- Oriol Fusté, PhD student at i2CAT and UPC, co-supervised with Joan A. Ruiz-de-Azua: transport protocols such as QUIC for challenged networks.
 Saarland University · Nanjing University · LIRMM · Concordia University · UNC
Funding